Manipulation with environment contact
Motion, force and trajectory planning for tasks where the object stays in contact with the environment, such as pivoting a heavy box about its edge.
To grasp and manipulate a wide range of objects, robotic hands and manipulators can make effective use of the environment. Many tasks are accomplished by using contacts between the grasped object and the environment, for example pivoting a heavy box about one of its edges instead of lifting it. We have developed algorithmic approaches for motion and force planning for manipulating objects this way, while considering the nonlinear contact constraints.
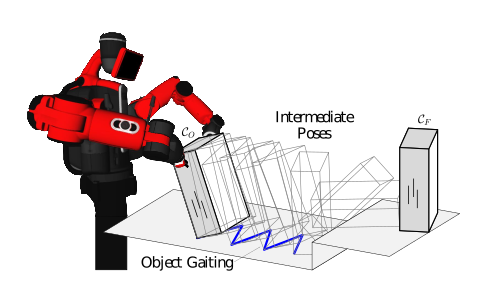
More recently, we developed a general formulation for path-constrained, time-optimized trajectory planning with environmental and object contacts.
Papers
A General Formulation for Path Constrained Time-Optimized Trajectory Planning with Environmental and Object Contacts
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Abu Dhabi, UAE, 2024
Motion and Force Planning for Manipulating Heavy Objects by Pivoting
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Prague, Czech Republic, 2021
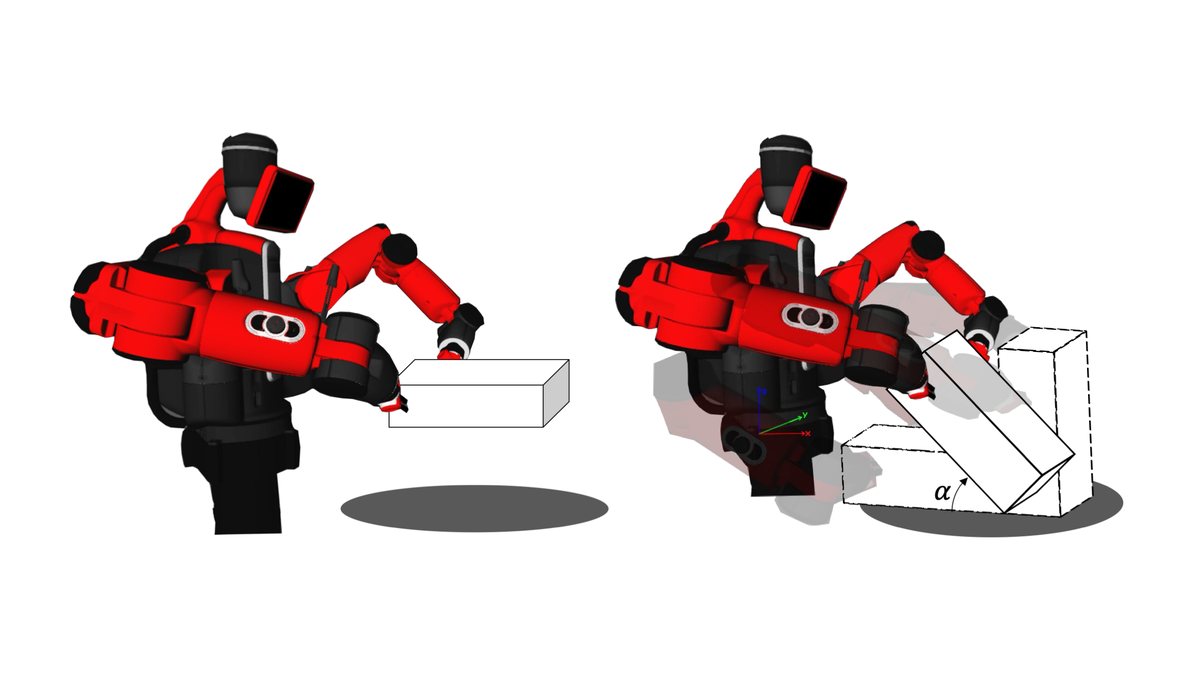
Hand-Object Contact Force Synthesis for Manipulating Objects by Exploiting Environment
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Las Vegas, NV, USA, 2020