Knowledge-Enabled Motion Generation for Complex Manipulation Tasks
Workshop on Geometric Representations: The Roles of Screw Theory, Lie Algebra, and Geometric Algebra, IEEE International Conference on Robotics and Automation (ICRA), London, UK, 2023
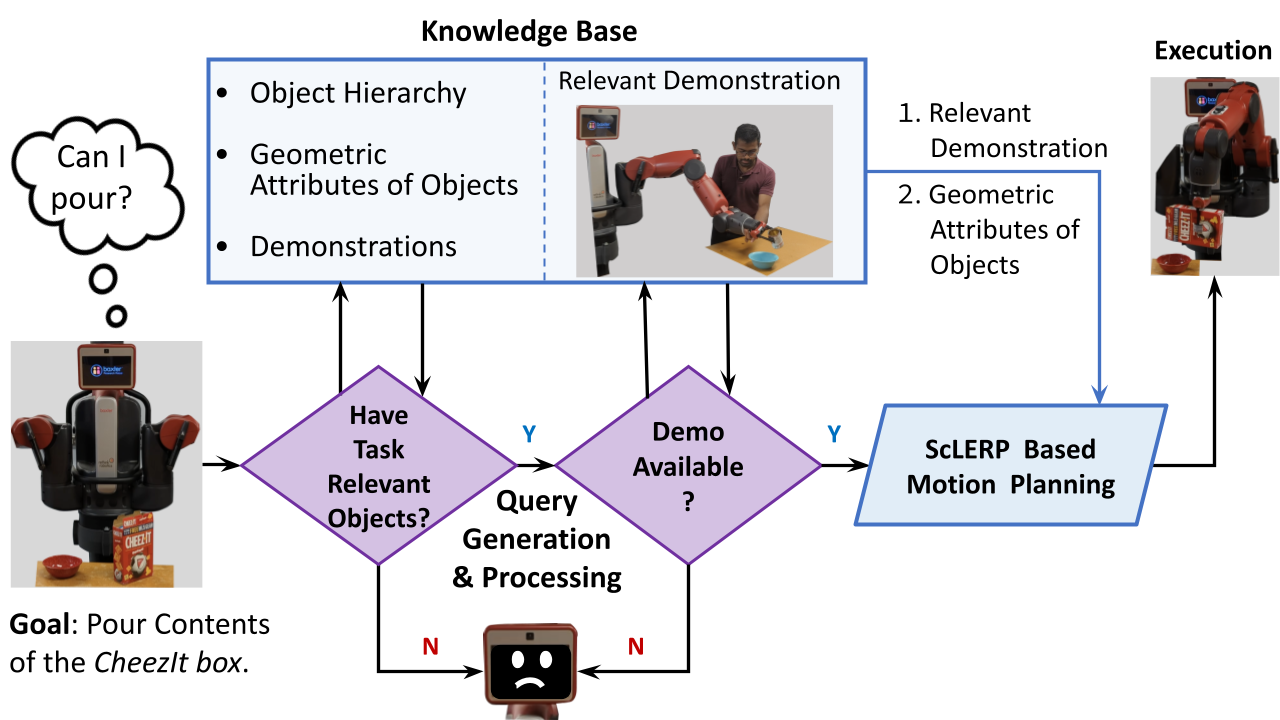
Recommended citation: D. Das, A. Patankar, F. Honda, D. Mahalingam, N. Chakraborty, C.R. Ramakrishnan, and I.V. Ramakrishnan. Knowledge-Enabled Motion Generation for Complex Manipulation Tasks. Workshop on Geometric Representations: The Roles of Screw Theory, Lie Algebra, and Geometric Algebra, IEEE International Conference on Robotics and Automation (ICRA), London, UK, 2023.