Design and Kinematic Analysis of a Novel Series-Parallel Hybrid Finger for Robotic Hands
ASME Journal of Mechanisms and Robotics, 2025
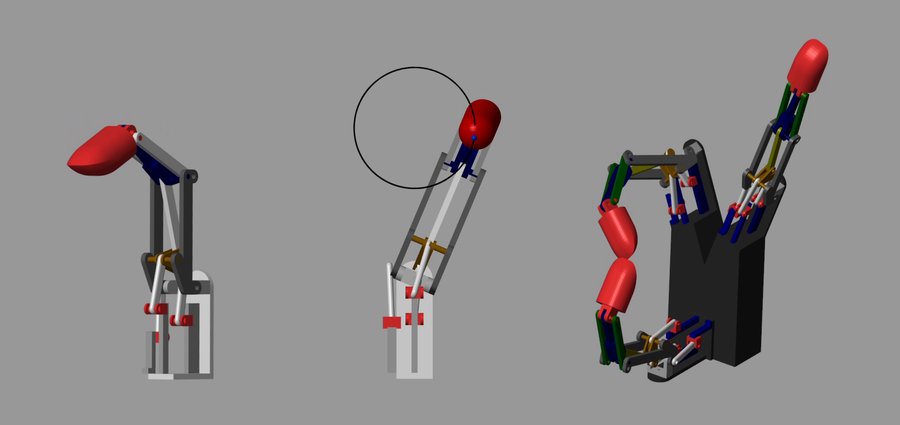
Recommended citation: T. Zaw, D. Mahalingam, N. Baiata, A. Patankar, and N. Chakraborty. Design and Kinematic Analysis of a Novel Series-Parallel Hybrid Finger for Robotic Hands. ASME Journal of Mechanisms and Robotics, 2025.